---
title: Webinars
description: Join our Franka Research Webinars to gain expert knowledge on the latest advancements in robotics, featuring industry leaders and innovative solutions.
image: https://franka.de/hs-fs/hubfs/V1%20Desktop.jpg?width=1200&name=V1%20Desktop.jpg
---
[](https://franka.de?hsLang=en)
[](https://franka.de/?hsLang=en)
Menu
- [Products](https://franka.de/products-overview)
- [Franka Research 3](https://franka.de/franka-research-3)
- [Diana 7 by Agile Robots](https://franka.de/diana-7)
- [Accessories](https://franka.de/accessories)
- [Prototypes](https://franka.de/product-prototypes)
- [Franka Research 3 Duo](https://franka.de/fr3-duo)
- [Mobile FR3 Duo](https://franka.de/mobile-fr3-duo)
- [Tactile Mobile Robot](https://franka.de/tmr)
- [Franka GELLO and GELLO Duo](https://franka.de/gello)
- [Applications](https://franka.de/applications)
- [Physical AI](https://franka.de/applications#physical-ai-applications)
- [Research](https://franka.de/applications#application-research)
- [Service / Innovative](https://franka.de/applications#application-innovation)
- [Art](https://franka.de/art)
- [Industry](https://franka.de/applications#application-industry)
- [Resources](https://franka.de/resources)
- [Product Documentation](https://franka.de/documents)
- [Development](https://franka.de/develop)
- [Community Contributions](https://franka.de/community)
- [Community Forum](https://www.franka-community.de/)
- [Webinars](https://franka.de/webinars)
- [Careers](https://franka.de/careers)
- [Company](https://franka.de/company)
- [About](https://franka.de/company)
- [Contact](https://franka.de/contact)
- [News](https://franka.de/news)
- [Events](https://franka.de/events)
- [Sales Partners](https://franka.de/partners)
English
- [Deutsch](https://franka.de/de/webinars)
- [日本語](https://franka.de/ja/webinars)
- [한국어](https://franka.de/ko/webinars)
- [English](https://franka.de/webinars)
- [中文 (Chinese)](https://www.franka-robotics.cn)
FRANKA RESEARCH HIGHLIGHTS
# WEBINARS
Discover the future of robotics and AI with our webinar series, hosted by Sven Parusel, Senior Vice President for Academia and Research of Franka Robotics.
With an extensive global network of top researchers, Sven Parusel brings together groundbreaking discoveries and influential insights in robotics.
Each month, he spotlights leading researchers whose work with Franka robots is transforming today’s innovations into tomorrow’s breakthroughs.
Join us to explore cutting-edge advancements and connect with the minds shaping the future of robotics!
Upcoming
New webinar soon available.
Recent Webinars
### Enter your details to watch
MONDAY, FEBRUARY 23, 2026
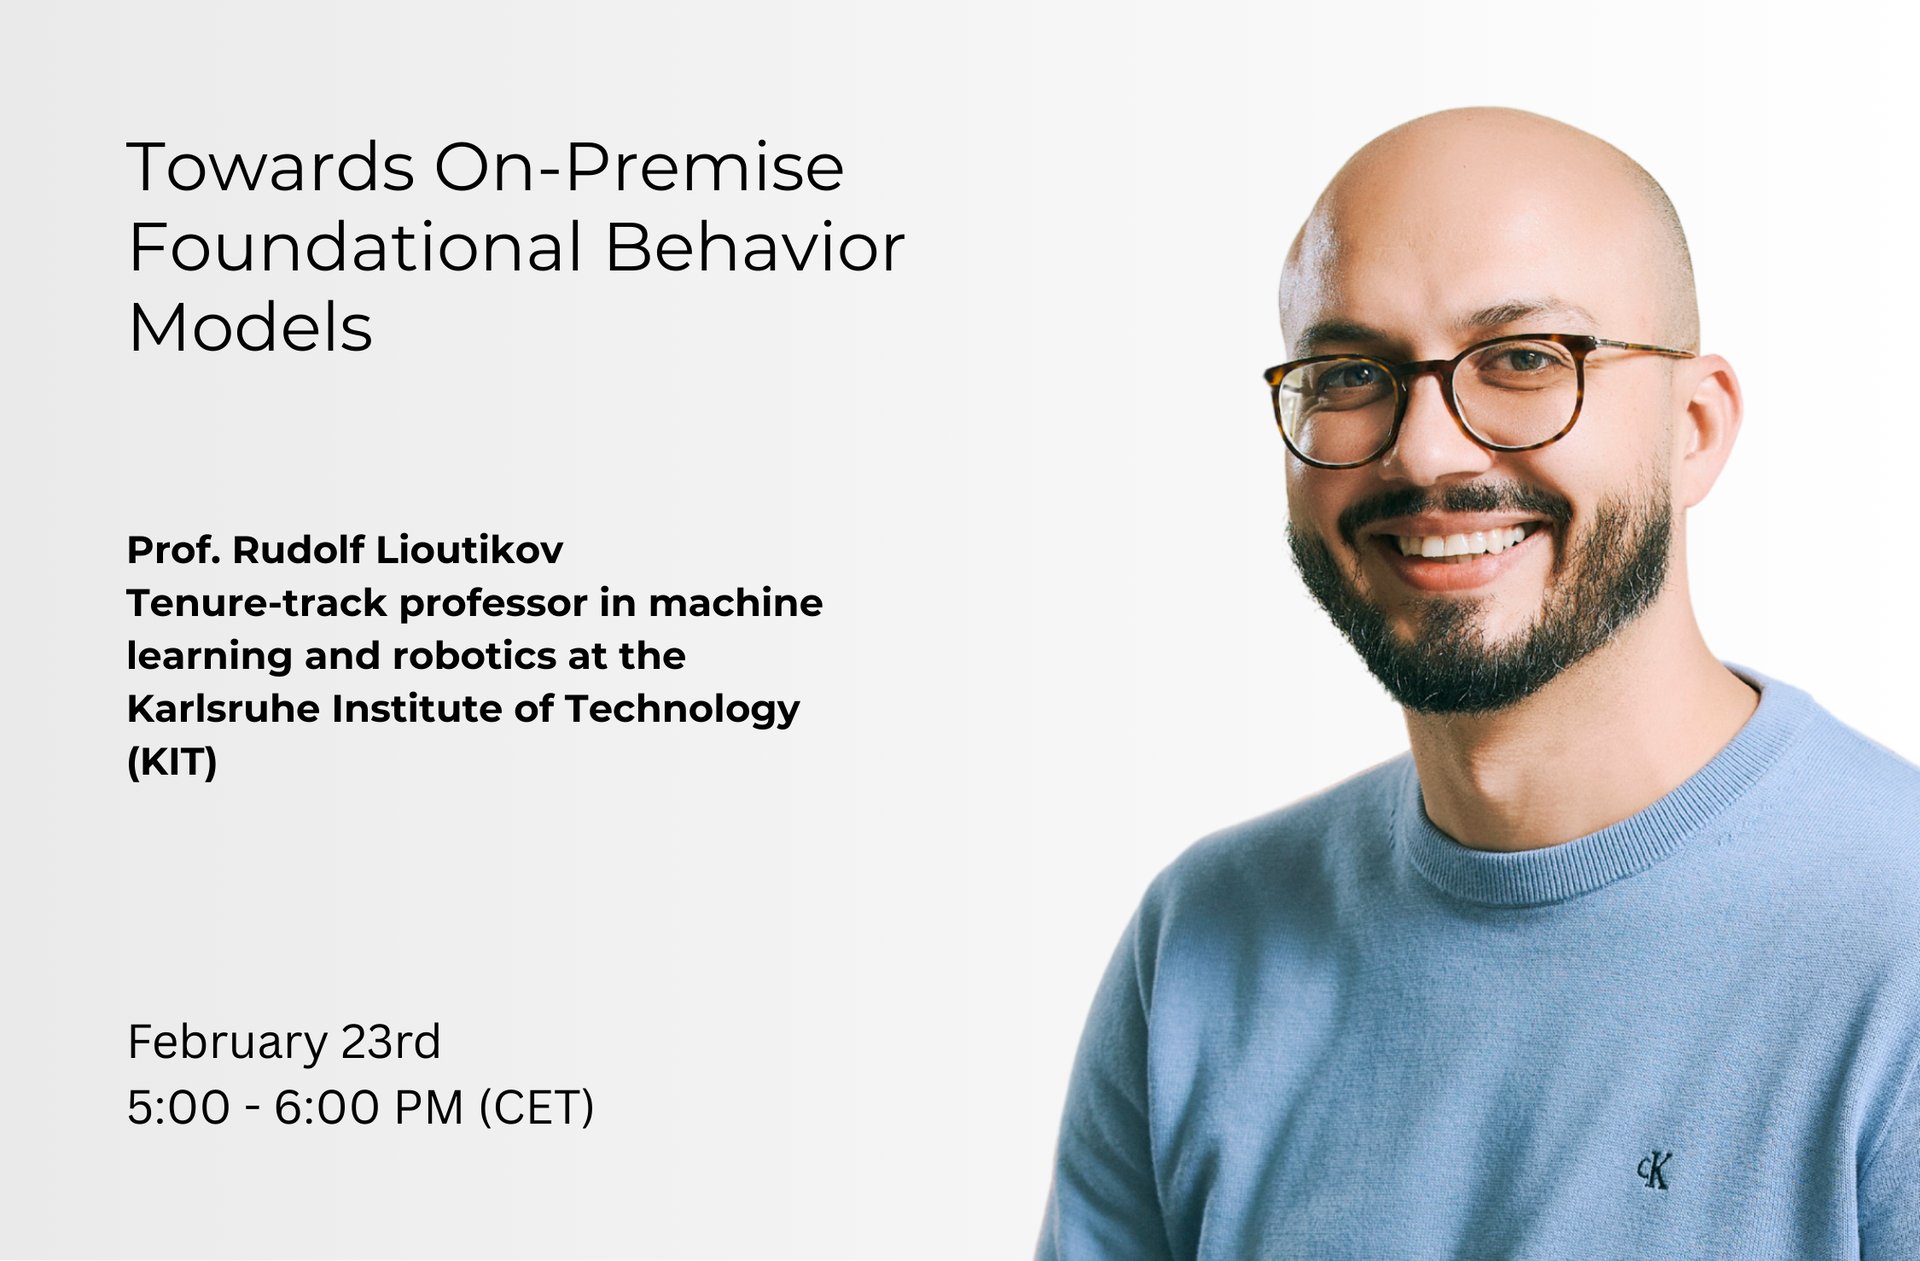
## TOWARDS ON-PREMISE FOUNDATIONAL BEHAVIOUR MODELS by Prof. Rudolf Lioutikov
The topic “Towards On-Premise Foundational Behavior Models” explored how recent breakthroughs in generative AI could be translated into practical, deployable intelligence for robotic systems. While diffusion models and vision-language models promised powerful, generalizable robot behavior, existing approaches were often too large, slow, data-hungry, and privacy-sensitive for real-world use. In this webinar, Rudolf Lioutikov presented recent advances that dramatically reduced model size, data requirements, and training and inference costs—spanning score-based diffusion, vision-language-action models, and action tokenization—charting a clear path toward efficient, privacy-preserving, on-premise foundational behavior models for robotics.
### Enter your details to watch
WEDNESDAY, DECEMBER 10, 2025
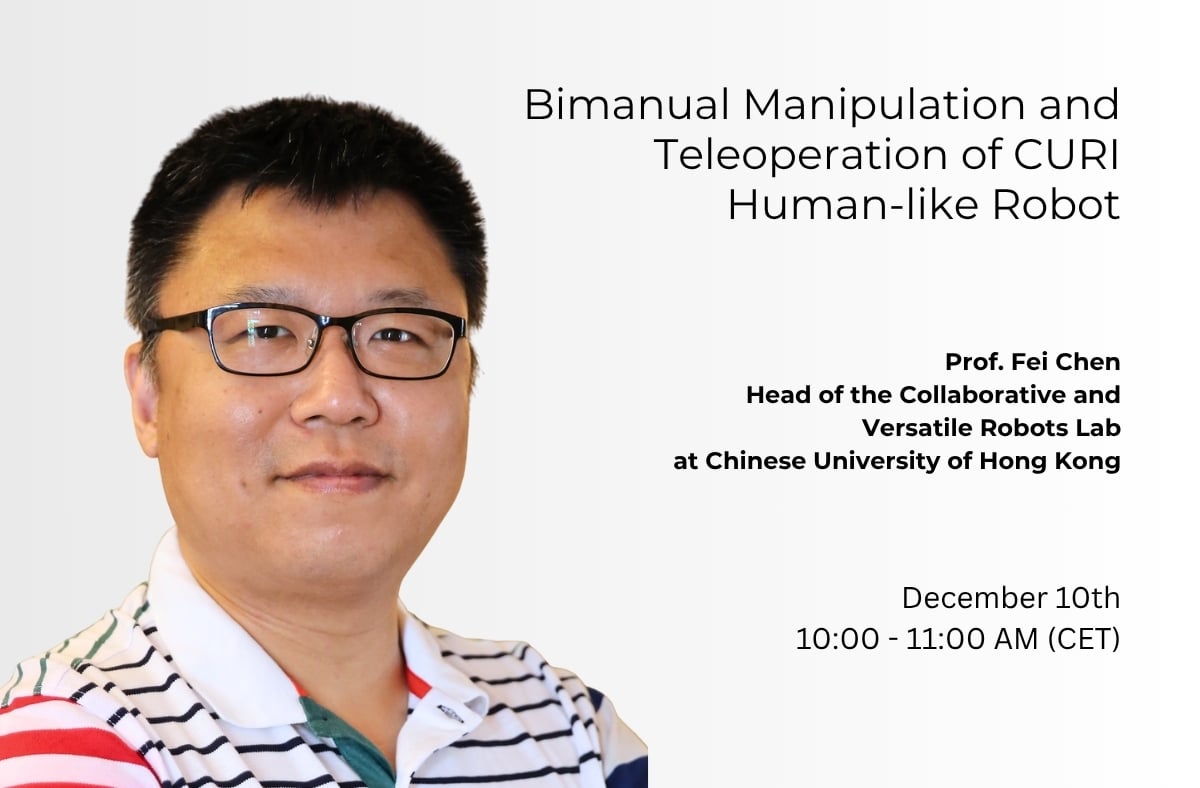
## BIMANUAL MANIPULATION AND TELEOPERATION OF CURI HUMAN-LIKE ROBOT by Prof. Fei Chen
Prof. Fei Chen, Head of the Collaborative and Versatile Robots Laboratory at The Chinese University of Hong Kong, focuses on humanoid bimanual manipulation and human-robot collaboration. Before joining CUHK, he led research at the Italian Institute of Technology and contributed to numerous international projects. With more than 100 publications, he is also actively involved in the IEEE community.
In his talk on bimanual manipulation and teleoperation of the CURI human-like robot, he showed how advanced control and interaction strategies are shaping the next generation of intelligent and versatile robotic systems.
### Enter your details to watch
THURSDAY, NOVEMBER 6, 2025
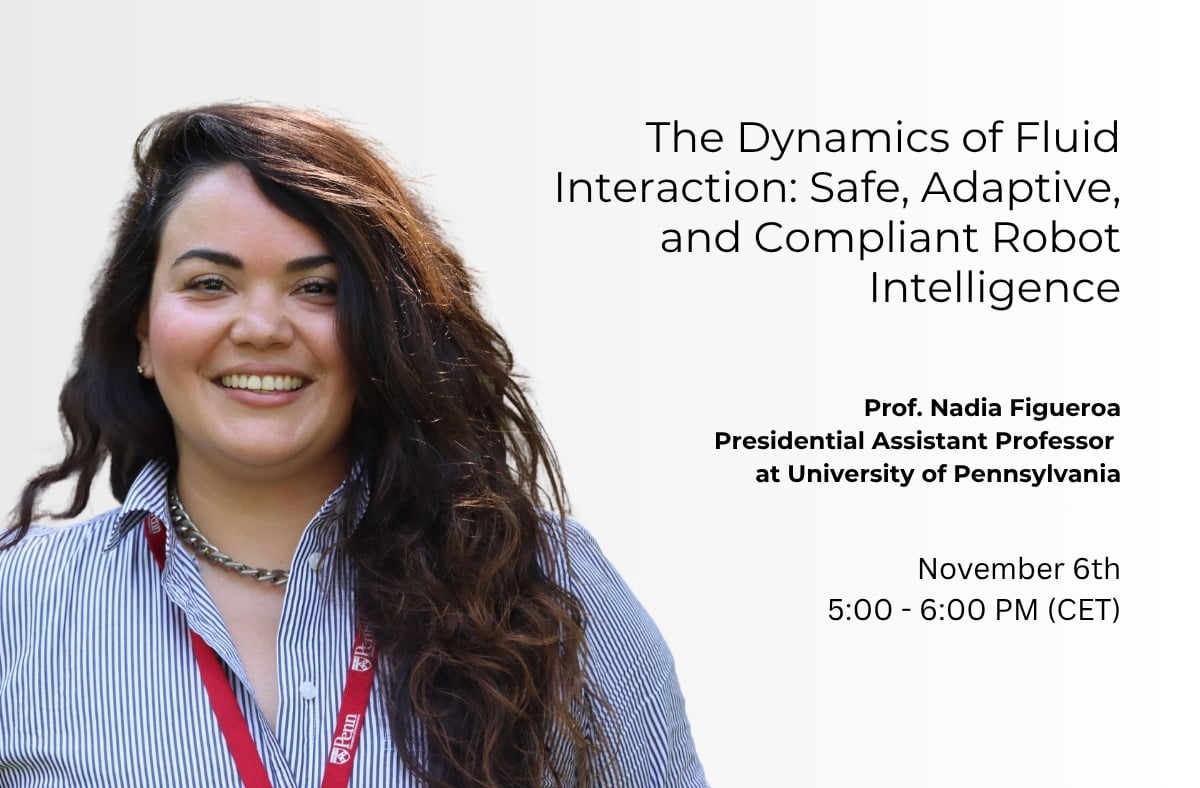
## THE DYNAMICS OF FLUID INTERACTION: SAFE, ADAPTIVE AND COMPLIANT ROBOT INTELLIGENCE by Prof. Nadia Figueroa
In this talk, Prof. Nadia Figueroa presented how her research on dynamical-systems-based learning, viability theory, and adaptive control enabled Franka robots to interact safely and naturally with humans and their environment. By combining concepts from control theory, machine learning, and human biomechanics, her work advanced the development of robotic systems that could adaptively respond to uncertainties and dynamic conditions during physical interaction. These approaches established a foundation for achieving fluid human-robot collaboration with formal guarantees of safety, efficiency, and robustness — key capabilities for the next generation of intelligent, human-centered robots.
### Enter your details to watch
WEDNESDAY, DECEMBER 11, 2024
## UNLOCKING GENERALIZATION FOR ROBOTICS VIA MODULARITY AND SCALE by Murtaza Dalal
In the recent webinar, Murtaza, a final-year PhD Candidate at Carnegie Mellon University, focused on building generalist robot systems by integrating modularity with large-scale learning. He explained how combining modular planning, learned control, and scene generation enables robots to perform complex, multi-stage tasks from text instructions. This approach addressed key challenges in robotics, such as multimodality, limited data, and safety concerns, pushing the limits of robot capabilities for diverse, real-world applications.
### Enter your details to watch
THURSDAY, NOVEMBER 14, 2024
## HOW CAN WE UNDERSTAND IF ROBOTS ARE SAFE FOR PHYSICAL INTERACTIONS? by Robin Jeanne Kirschner
In our latest webinar, together with our guest speaker Robin Jeanne Kirschner, Research Assistant at the Munich Institute of Robotics and Machine Intelligence (MIRMI) at the Technical University of Munich, we shared insights from her research on concepts for physical and cognitive safety in human-robot interaction and assessing robots' ability for tactile interaction. Robin provided an in-depth look at how databases can be developed to understand human safety and evaluate robots' features and application designs for physical interactions, ensuring safe interaction with the environment.
### Enter your details to watch
MONDAY, SEPTEMBER 16, 2024
## DESIGNING CONTACT-RICH ROBOT CONTROL FRAMEWORKS FOR HUMAN-ROBOT INTERACTION by Idil Özdamar
In this webinar, Idil Özdamar, a Ph.D. student at the Human-Robot Interfaces and Interaction Lab (HRI²) at the Italian Institute of Technology (IIT) will share insights into the latest advancements in Human-Robot Interaction (HRI) and explore the impact of Franka robots on enhancing human-machine collaboration. The discussion will also cover how these cutting-edge technologies are tackling real-world challenges with innovative and effective solutions.
### Enter your details to watch
MONDAY, MAY 27, 2024
## FRUGAL LEARNING OF MANIPULATION SKILLS IN ROBOTICS by Dr. Sylvain Calinon
In a recent webinar, Dr. Sylvain Calinon, a Senior Research Scientist at Idiap Research Institute and Lecturer at EPFL, shared his expertise on teaching robots manipulation skills—an ability that comes naturally to humans but is complex for machines. He explored how robots can learn from limited training data and emphasized the importance of developing versatile data and geometric structures to enable robots to perform a wide range of tasks.
### Enter your details to watch
MONDAY, APRIL 22, 2024
## ROBOT MODELING & CONTROL IN THE ERA OF MACHINE LEARNING by Dr. Cosimo Della Santina
Professor Cosimo Della Santina from Delft University of Technology and Guest Scientist at the Deutsches Zentrum für Luft- und Raumfahrt e.V. delved into the challenges of robotics research, focusing on the modeling and control of complex mechanical systems. His presentation provided valuable insights into the intricate work required to advance robotic technology.
## FOLLOW US
1. [Follow us on Facebook](https://www.facebook.com/frankarobotics/)
2. [Follow us on LinkedIn](https://www.linkedin.com/company/frankarobotics)
3. [Follow us on X](https://twitter.com/FRANKAROBOTICS)
4. [Follow us on Instagram](https://www.instagram.com/frankarobotics/)
5. [Follow us on YouTube](https://www.youtube.com/channel/UCjvmirH4BRbWoQwYO4EmXFQ)
6. [Contact us](https://franka.de/contact)
1. [Imprint](https://franka.de/imprint)
2. [Privacy Policy](https://franka.de/privacy-policy)
3. [GTC](https://franka.de/hubfs/New_GTC_EN_FrankaRobotics_040226.pdf)
4. [AGB](https://franka.de/hubfs/New_GTC_GER_FrankaRobotics_040226.pdf)
Franka Robotics GmbH
Koppstraße 12
81379 Munich – Germany
Phone: +49 89 2006069 20
Email: [info@franka.de](mailto:sales@franka.de)
Mo. - Fr. 8:30am - 5:00pm CEST
© 2026 Franka Robotics GmbH.
All rights reserved
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/video_assets/368606947530/inherited/web_optimized.mp4",
"dateModified" : "2026-02-24T13:01:29.396Z",
"duration" : "PT1H10M1.088S",
"height" : 1080,
"name" : "Towards On-Premise Foundational Behavior Models-1",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Towards%20On-Premise%20Foundational%20Behavior%20Models-1.mp4/medium.jpg",
"uploadDate" : "2026-02-24T13:01:13.614Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Bimanual%20Manipulation%20and%20Teleoperation%20of%20CURI%20Human-like%20Robot.mp4",
"dateModified" : "2025-12-12T08:01:42.697Z",
"duration" : "PT1H7M43S",
"height" : 1080,
"name" : "Bimanual Manipulation and Teleoperation of CURI Human-like Robot",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Bimanual%20Manipulation%20and%20Teleoperation%20of%20CURI%20Human-like%20Robot.mp4/medium.jpg",
"uploadDate" : "2025-12-12T07:59:57.405Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/The%20Dynamics%20of%20Fluid%20Interaction_%20Safe%2c%20Adaptive%20and%20Compliant%20Robot%20Intelligence.mp4",
"dateModified" : "2025-11-07T08:15:35.945Z",
"duration" : "PT1H12M28S",
"height" : 1080,
"name" : "The Dynamics of Fluid Interaction_ Safe, Adaptive and Compliant Robot Intelligence",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/The%20Dynamics%20of%20Fluid%20Interaction_%20Safe%2c%20Adaptive%20and%20Compliant%20Robot%20Intelligence.mp4/medium.jpg",
"uploadDate" : "2025-11-07T08:15:15.737Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://stream.mux.com/02gdH7livyCw4HQvwgCapqoIGBMYs8b1aKAq229Qt8rk/capped-1080p.mp4",
"dateModified" : "2024-12-12T08:11:42.823Z",
"duration" : "PT1H39S",
"height" : 1080,
"name" : "Unlocking Generalization for Robotics via Modularity and Scale ",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Unlocking%20Generalization%20for%20Robotics%20via%20Modularity%20and%20Scale%20.mp4/medium.jpg",
"uploadDate" : "2024-12-12T08:11:42.817Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Franka%20Research%20Highlight%20Webinar_%20How%20Can%20We%20Understand%20if%20Robots%20are%20Safe%20for%20Physical%20Interactions_%20.mp4",
"dateModified" : "2024-11-15T12:37:45.796Z",
"description" : "How can we unterstand if a robot is fit for safe physical Interactions?",
"duration" : "PT1H10M49.152S",
"height" : 1080,
"name" : "Franka Research Highlights Webinar",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Franka%20Research%20Highlight%20Webinar_%20How%20Can%20We%20Understand%20if%20Robots%20are%20Safe%20for%20Physical%20Interactions_%20.mp4/medium.jpg",
"uploadDate" : "2024-11-15T12:32:00.163Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Webinars/Franka%20Research%20Webinar_Idil%20%C3%96zdamar_16Sep24.mp4",
"dateModified" : "2024-10-04T08:43:13.507Z",
"duration" : "PT57M40S",
"height" : 1080,
"name" : "Franka Research Webinar_Idil Özdamar_16Sep24",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Webinars/Franka%20Research%20Webinar_Idil%20%C3%96zdamar_16Sep24.mp4/medium.jpg",
"uploadDate" : "2024-10-04T07:11:15.661Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Webinars/Franka%20Research%20Webinar_Sylvian%20Calinon_27May24.mp4",
"dateModified" : "2024-10-04T08:47:20.401Z",
"duration" : "PT58M39S",
"height" : 1080,
"name" : "Franka Research Webinar_Sylvian Calinon_27May24",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Webinars/Franka%20Research%20Webinar_Sylvian%20Calinon_27May24.mp4/medium.jpg",
"uploadDate" : "2024-10-04T08:47:20.396Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@type" : "VideoObject",
"contentUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Webinars/Franka%20Research%20Webinar_Cosimo%20Della%20Santina_22Apr24.mp4",
"dateModified" : "2024-10-04T08:43:19.991Z",
"duration" : "PT1H2M15S",
"height" : 1080,
"name" : "Franka Research Webinar_Cosimo Della Santina_22Apr24",
"thumbnailUrl" : "https://24883234.fs1.hubspotusercontent-eu1.net/hubfs/24883234/Webinars/Franka%20Research%20Webinar_Cosimo%20Della%20Santina_22Apr24.mp4/medium.jpg",
"uploadDate" : "2024-10-04T08:42:04.567Z",
"width" : 1920
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/#organization",
"@type" : "Organization",
"brand" : {
"@type" : "Brand",
"name" : "Franka Robotics"
},
"legalName" : "Franka Robotics GmbH",
"logo" : {
"@id" : "https://franka.de/#logo",
"@type" : "ImageObject",
"contentUrl" : "https://franka.de/hubfs/logo-and-claim.svg",
"url" : "https://franka.de/hubfs/logo-and-claim.svg"
},
"name" : "Franka Robotics",
"parentOrganization" : {
"@type" : "Organization",
"name" : "Agile Robots"
},
"sameAs" : [ "https://www.facebook.com/frankarobotics/", "https://www.linkedin.com/company/frankarobotics", "https://twitter.com/FRANKAROBOTICS", "https://www.instagram.com/frankarobotics/", "https://www.youtube.com/channel/UCjvmirH4BRbWoQwYO4EmXFQ" ],
"url" : "https://franka.de/"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/#website",
"@type" : "WebSite",
"inLanguage" : "en",
"name" : "Franka Robotics",
"publisher" : {
"@id" : "https://franka.de/#organization"
},
"url" : "https://franka.de/"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#webpage",
"@type" : [ "WebPage", "CollectionPage" ],
"about" : {
"@id" : "https://franka.de/webinars#webinars"
},
"breadcrumb" : {
"@id" : "https://franka.de/webinars#breadcrumb"
},
"description" : "Discover Franka Research Highlights webinars featuring leading researchers and experts discussing robotics, artificial intelligence, robot learning, manipulation, control, teleoperation and human-robot interaction.",
"inLanguage" : "en",
"isPartOf" : {
"@id" : "https://franka.de/#website"
},
"mainEntity" : {
"@id" : "https://franka.de/webinars#webinars"
},
"name" : "Webinars | Franka Robotics",
"publisher" : {
"@id" : "https://franka.de/#organization"
},
"url" : "https://franka.de/webinars"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#breadcrumb",
"@type" : "BreadcrumbList",
"itemListElement" : [ {
"@type" : "ListItem",
"item" : "https://franka.de/",
"name" : "Home",
"position" : 1
}, {
"@type" : "ListItem",
"item" : "https://franka.de/webinars",
"name" : "Webinars",
"position" : 2
} ]
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#webinars",
"@type" : "ItemList",
"description" : "Webinars featuring researchers and experts discussing robotics, artificial intelligence, robot learning, manipulation, control, teleoperation and human-robot interaction.",
"itemListElement" : [ {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#rudolf-lioutikov"
},
"name" : "Towards On-Premise Foundational Behaviour Models",
"position" : 1
}, {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#fei-chen"
},
"name" : "Bimanual Manipulation and Teleoperation of CURI Human-Like Robot",
"position" : 2
}, {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#nadia-figueroa"
},
"name" : "The Dynamics of Fluid Interaction: Safe, Adaptive and Compliant Robot Intelligence",
"position" : 3
}, {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#murtaza-dalal"
},
"name" : "Unlocking Generalization for Robotics via Modularity and Scale",
"position" : 4
}, {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#robin-kirschner"
},
"name" : "How Can We Understand If Robots Are Safe for Physical Interactions?",
"position" : 5
}, {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#idil-ozdamar"
},
"name" : "Designing Contact-Rich Robot Control Frameworks for Human-Robot Interaction",
"position" : 6
}, {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#sylvain-calinon"
},
"name" : "Frugal Learning of Manipulation Skills in Robotics",
"position" : 7
}, {
"@type" : "ListItem",
"item" : {
"@id" : "https://franka.de/webinars#cosimo-della-santina"
},
"name" : "Robot Modeling & Control in the Era of Machine Learning",
"position" : 8
} ],
"name" : "Franka Research Highlights webinars",
"numberOfItems" : 8
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#rudolf-lioutikov",
"@type" : "Event",
"description" : "The webinar explored how recent breakthroughs in generative AI could be translated into practical, deployable intelligence for robotic systems. Topics included score-based diffusion, vision-language-action models and action tokenization, with a focus on efficient, privacy-preserving, on-premise foundational behaviour models for robotics.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "Towards On-Premise Foundational Behaviour Models",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Prof. Rudolf Lioutikov"
},
"startDate" : "2026-02-23"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#fei-chen",
"@type" : "Event",
"description" : "The webinar explored bimanual manipulation and teleoperation of the CURI human-like robot and discussed advanced control and interaction strategies shaping the next generation of intelligent and versatile robotic systems.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "Bimanual Manipulation and Teleoperation of CURI Human-Like Robot",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Prof. Fei Chen"
},
"startDate" : "2025-12-10"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#nadia-figueroa",
"@type" : "Event",
"description" : "The webinar explored how dynamical-systems-based learning, viability theory and adaptive control can enable Franka robots to interact safely and naturally with humans and their environment, supporting fluid human-robot collaboration.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "The Dynamics of Fluid Interaction: Safe, Adaptive and Compliant Robot Intelligence",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Prof. Nadia Figueroa"
},
"startDate" : "2025-11-06"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#murtaza-dalal",
"@type" : "Event",
"description" : "The webinar explored how modularity and large-scale learning can be combined to build generalist robot systems capable of performing complex, multi-stage tasks from text instructions, addressing challenges including multimodality, limited data and safety.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "Unlocking Generalization for Robotics via Modularity and Scale",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Murtaza Dalal"
},
"startDate" : "2024-12-11"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#robin-kirschner",
"@type" : "Event",
"description" : "The webinar explored physical and cognitive safety in human-robot interaction, tactile interaction and approaches for understanding human safety and evaluating robot features and application designs for physical interactions.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "How Can We Understand If Robots Are Safe for Physical Interactions?",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Robin Jeanne Kirschner"
},
"startDate" : "2024-11-14"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#idil-ozdamar",
"@type" : "Event",
"description" : "The webinar explored advancements in human-robot interaction, contact-rich robot control and the impact of Franka robots on enhancing human-machine collaboration.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "Designing Contact-Rich Robot Control Frameworks for Human-Robot Interaction",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Idil Özdamar"
},
"startDate" : "2024-09-16"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#sylvain-calinon",
"@type" : "Event",
"description" : "The webinar explored how robots can learn manipulation skills from limited training data and how versatile data and geometric structures can support robots performing a wide range of tasks.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "Frugal Learning of Manipulation Skills in Robotics",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Dr. Sylvain Calinon"
},
"startDate" : "2024-05-27"
}
```
```json
{
"@context" : "https://schema.org",
"@id" : "https://franka.de/webinars#cosimo-della-santina",
"@type" : "Event",
"description" : "The webinar explored challenges in robotics research involving the modeling and control of complex mechanical systems and discussed insights into advancing robotic technology.",
"eventAttendanceMode" : "https://schema.org/OnlineEventAttendanceMode",
"location" : {
"@type" : "Place",
"name" : "Online"
},
"name" : "Robot Modeling & Control in the Era of Machine Learning",
"organizer" : {
"@id" : "https://franka.de/#organization"
},
"performer" : {
"@type" : "Person",
"name" : "Dr. Cosimo Della Santina"
},
"startDate" : "2024-04-22"
}
```